←Home
When Vision Models Learn to Move
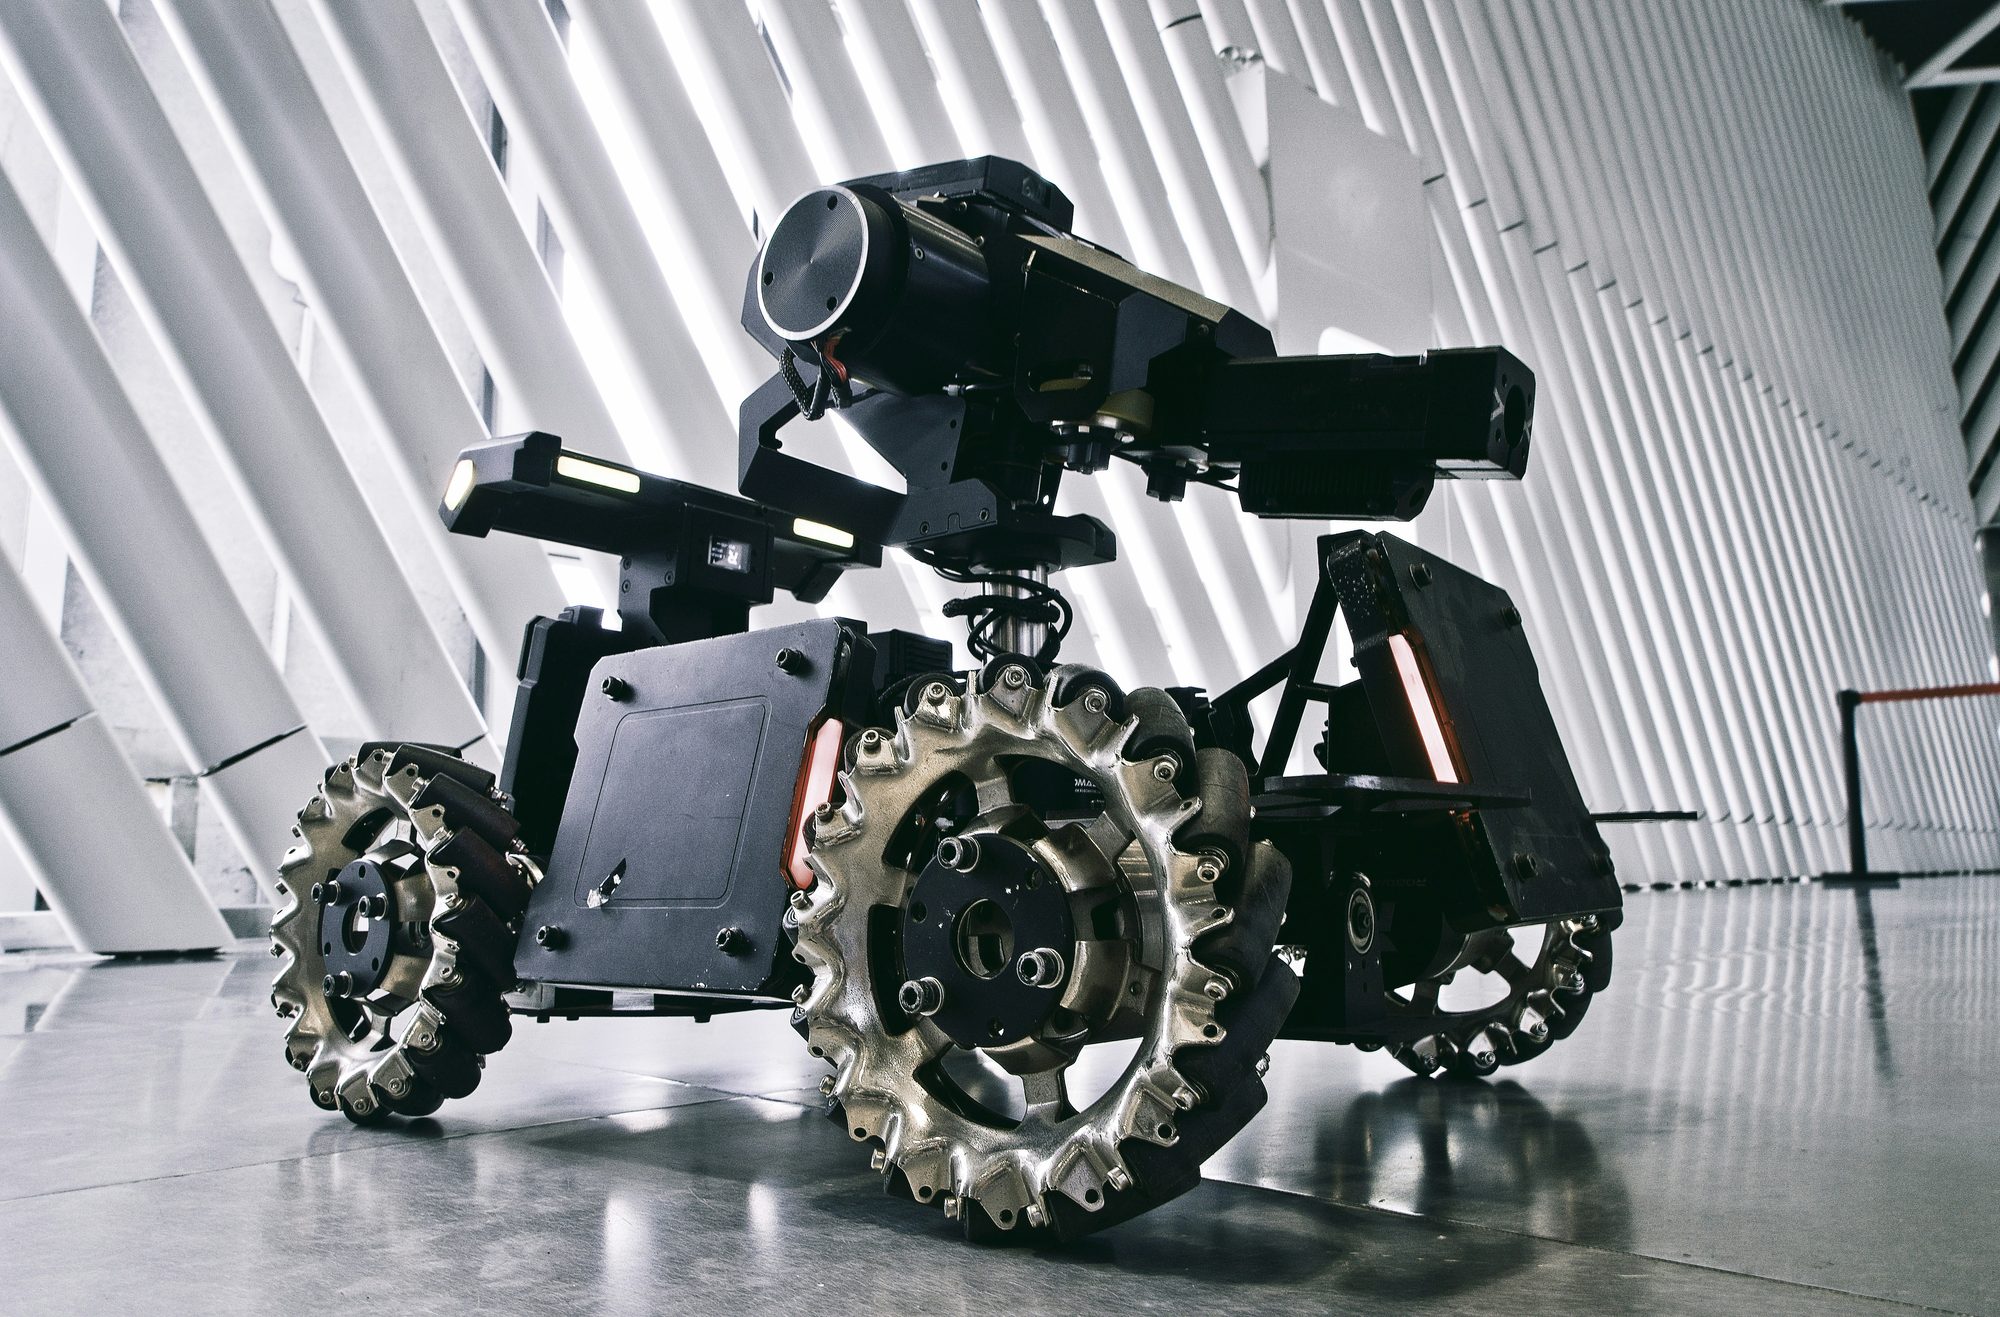
How vision-language models are being turned into robot controllers, either as end-to-end vision-language-action policies or as agents driving a robot through an interface, and how well each approach holds up in the physical world.